Conrad Kelsay

I'm a junior studying mechanical engineering at Oregon State University, with a strong interest in hardware design, robotics, and the development of emerging technologies. I enjoy engineering challenges that bring together mechanical, electrical, and control systems, especially when they involve taking ideas from initial design through physical implementation. My experience spans semiconductor manufacturing at Intel, industrial automation at Talos Engineering, and hands-on mechanical design through Oregon State's Mars Rover team.

Now
Module Engineering Intern, Intel · Hillsboro, OR
Previously
Automation Engineering Intern, Talos Engineering · Summer 2026
At school
End-Effector Team Lead, OSU Mars Rover
Studying
B.S. Mechanical Engineering, Robotic Control Option · 3.85 GPA · 2028
Looking for
Summer 2027 internships in robotics, automation, controls, and manufacturing

Experience

Sep 2026 – Present

Intel

Module Engineering Intern · Hillsboro, OR

  • Support semiconductor manufacturing operations across Cross Module Support, working with wafer handling and material-flow processes
  • Help engineering teams with equipment and process troubleshooting, data review, and verification to improve reliability and wafer movement through the fab
  • Work across process, equipment, and manufacturing teams in a high-volume fab, with hands-on exposure to automated wafer handling and contamination control
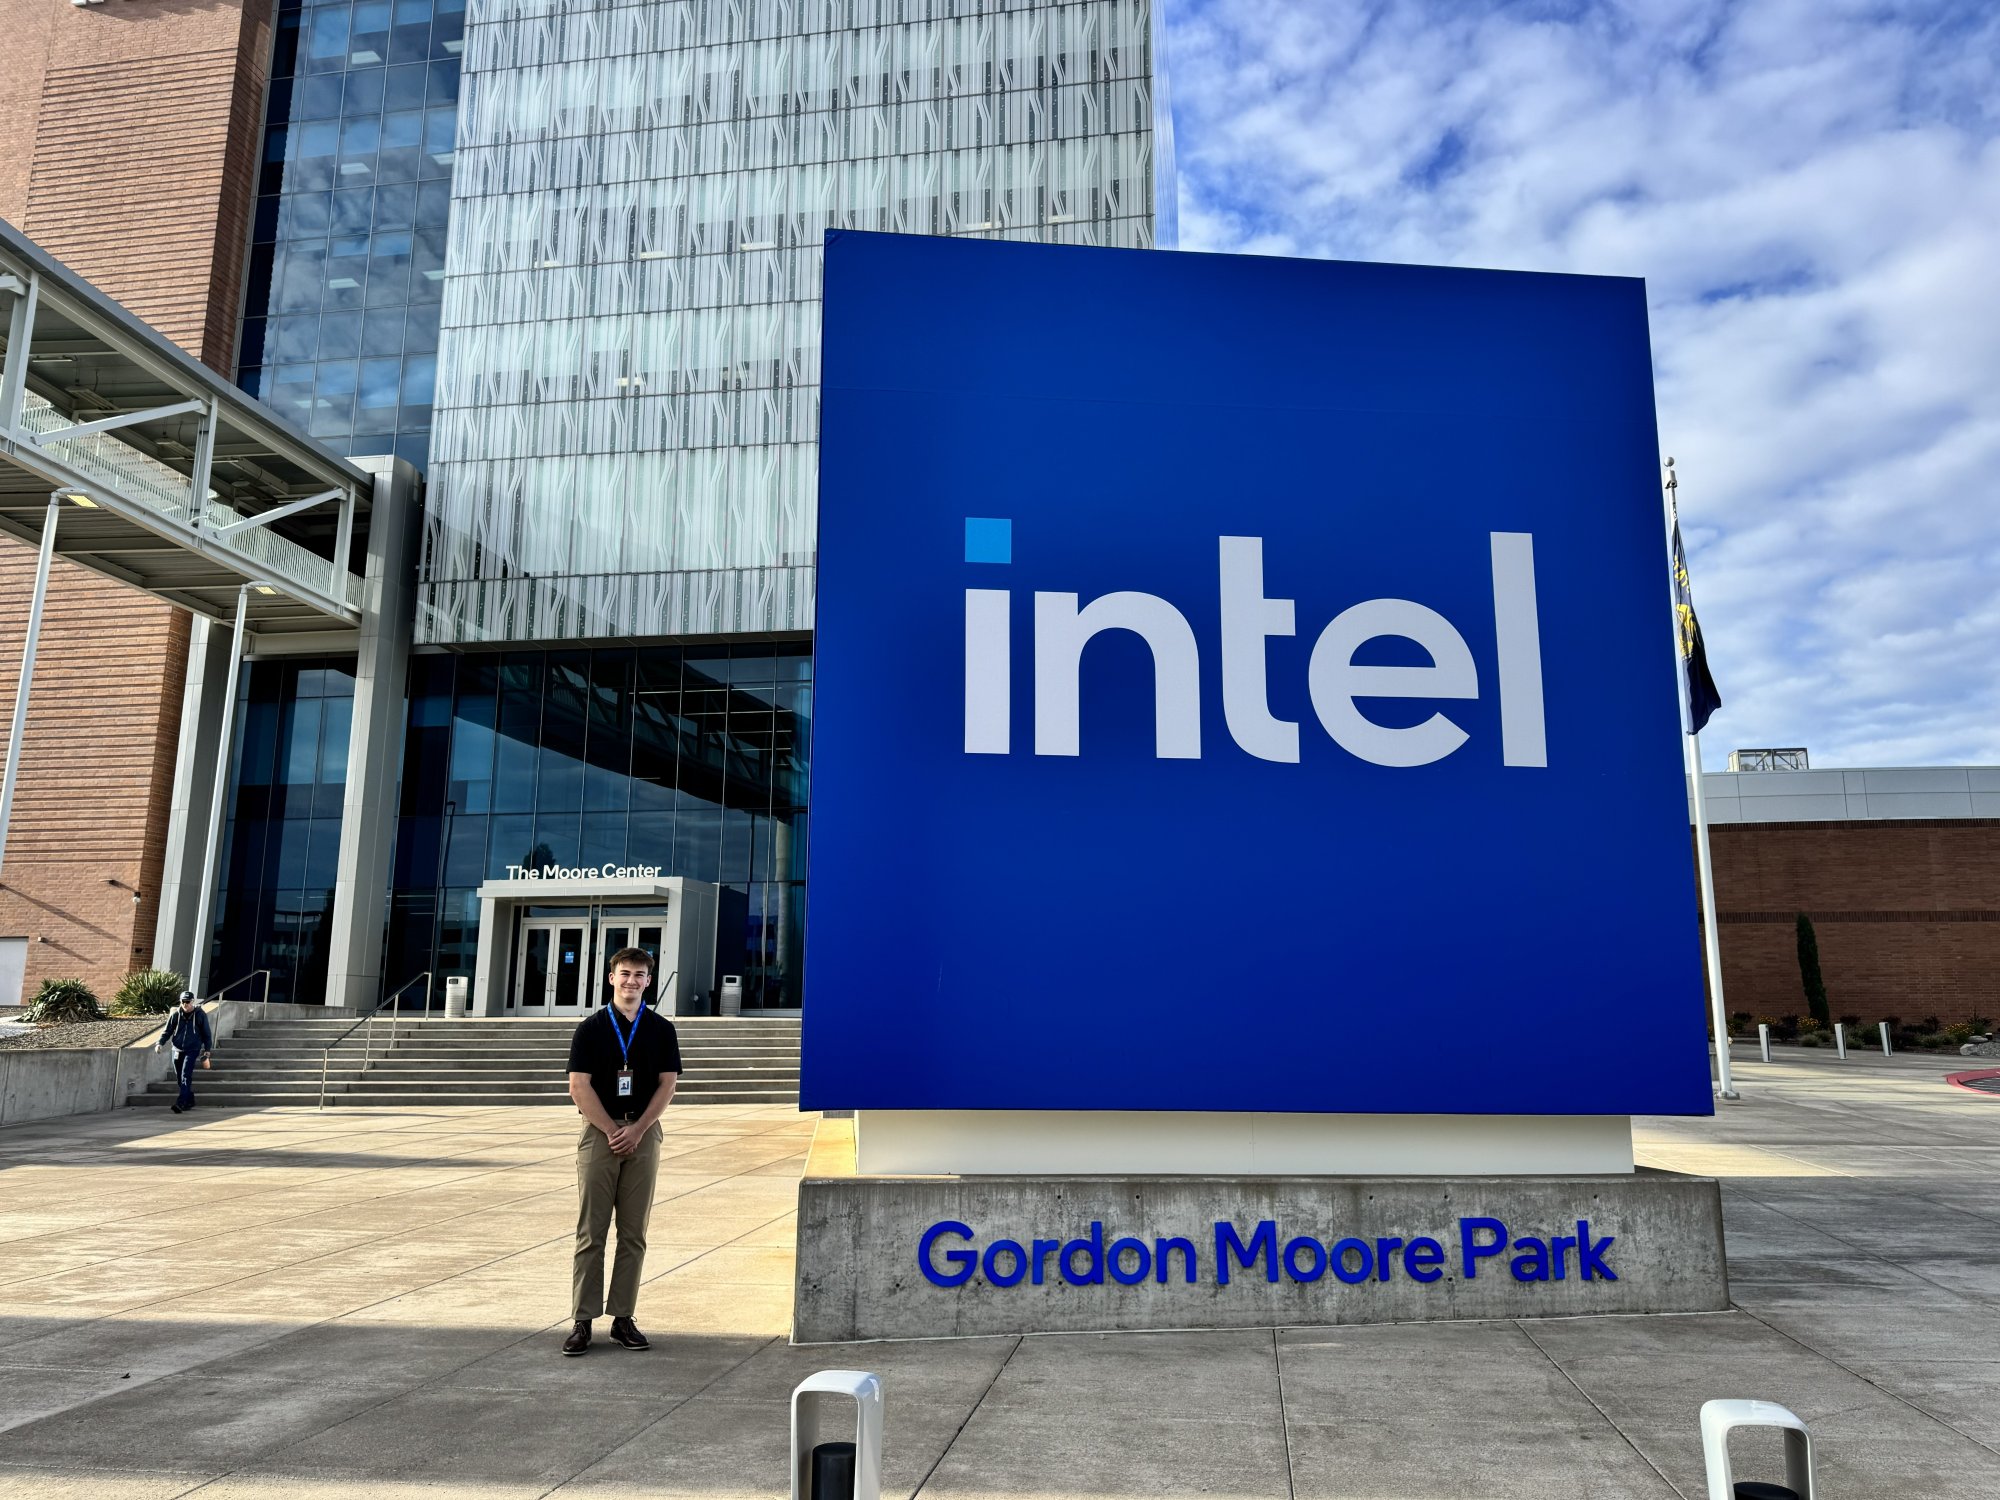
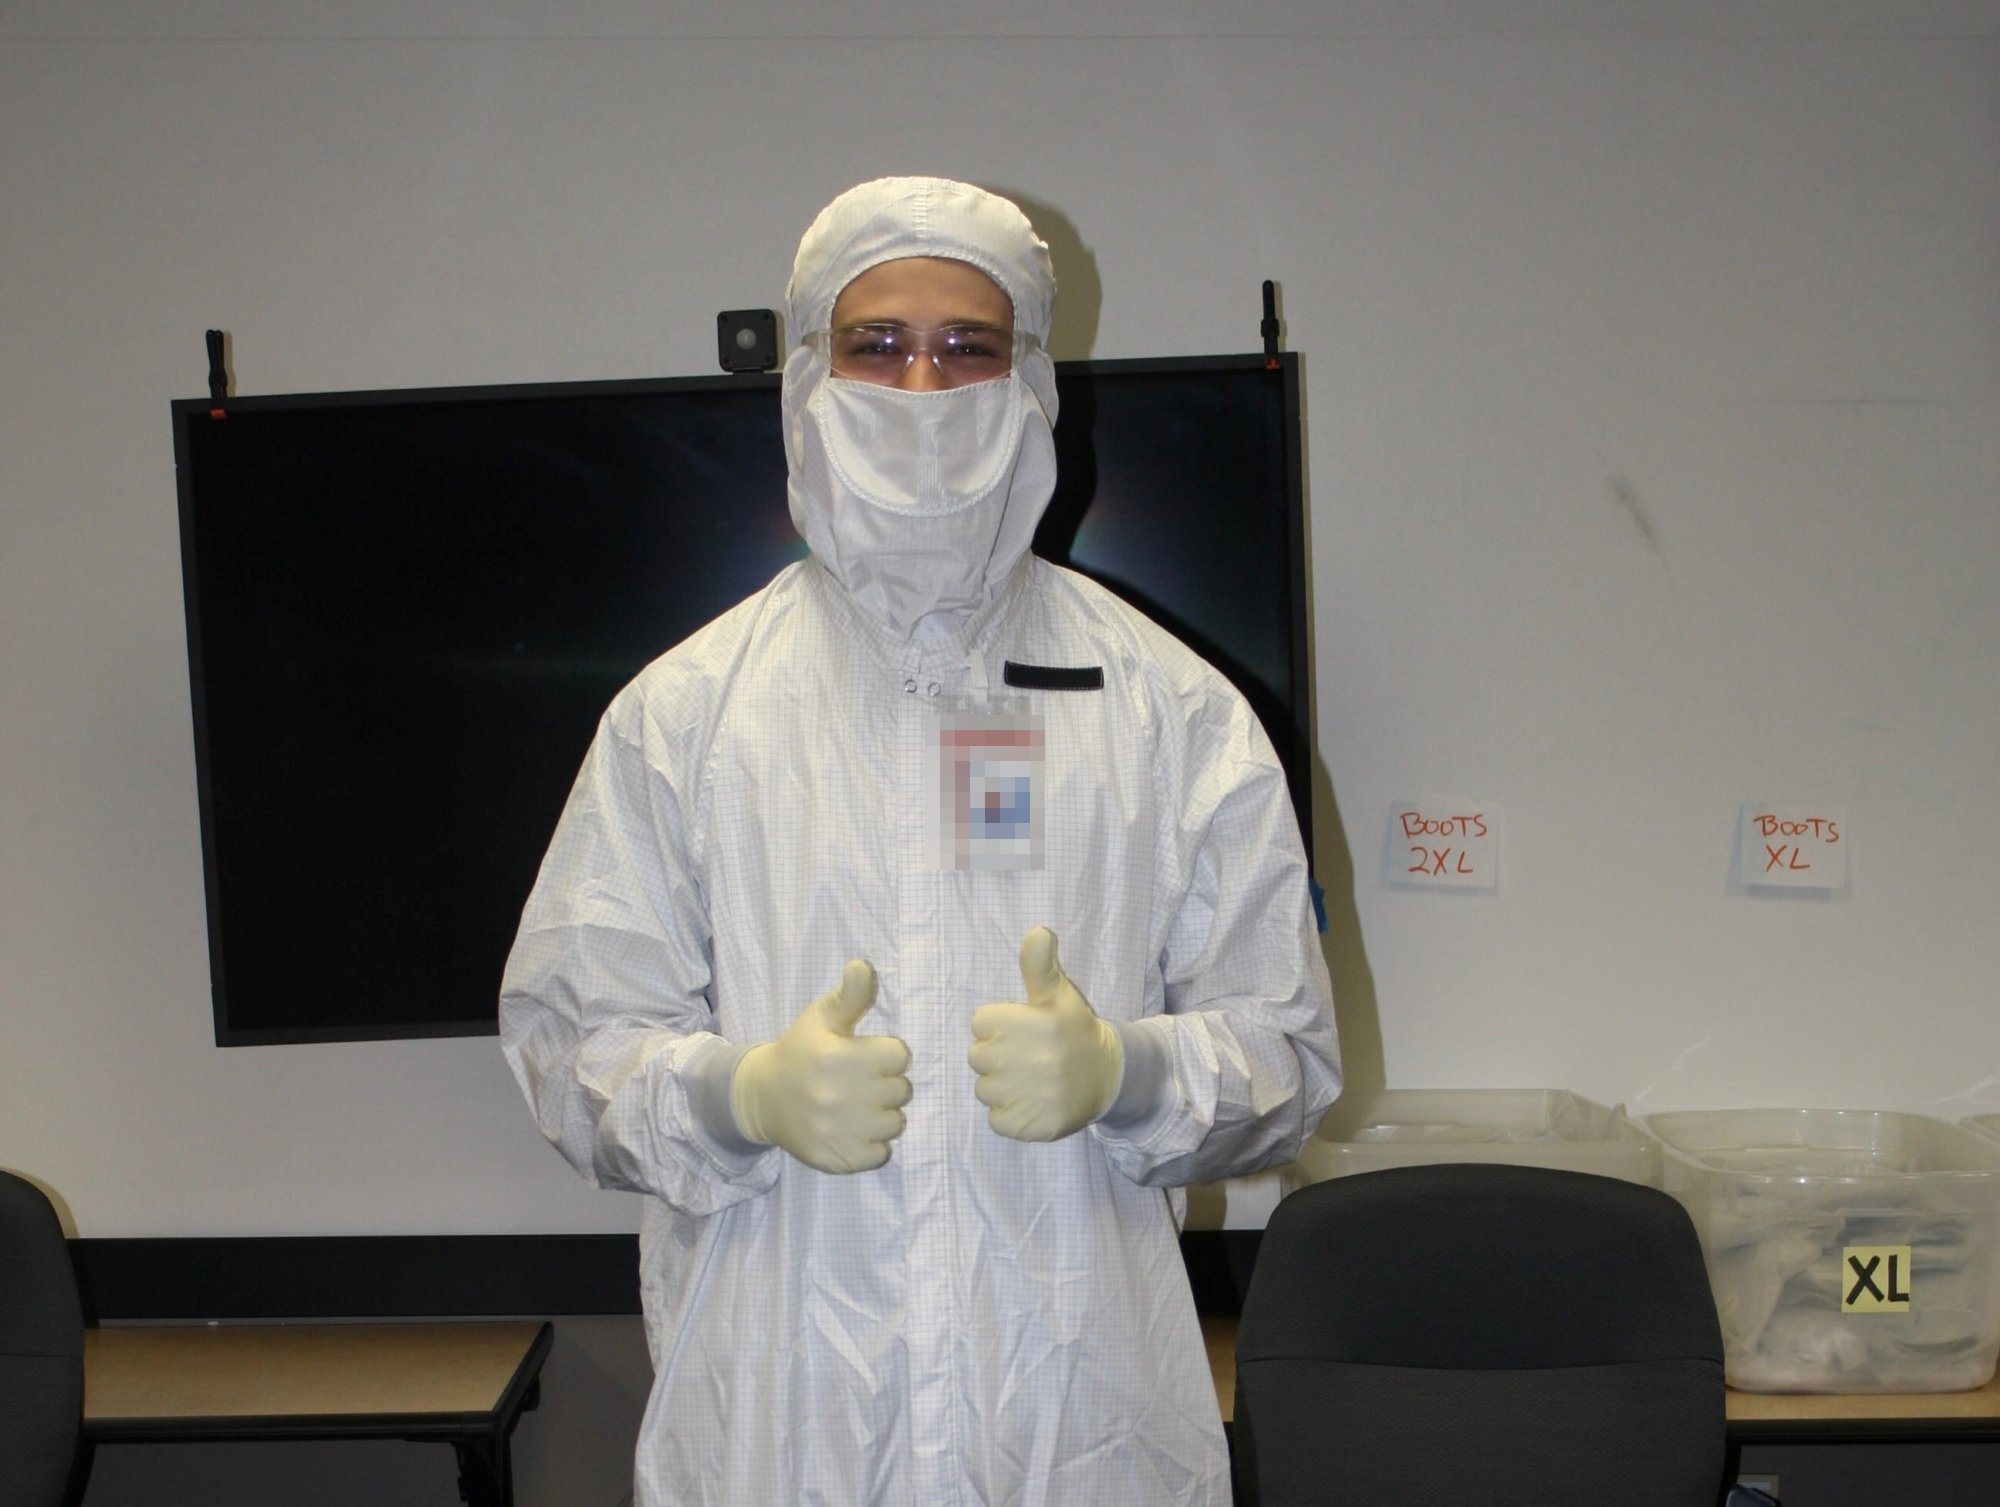
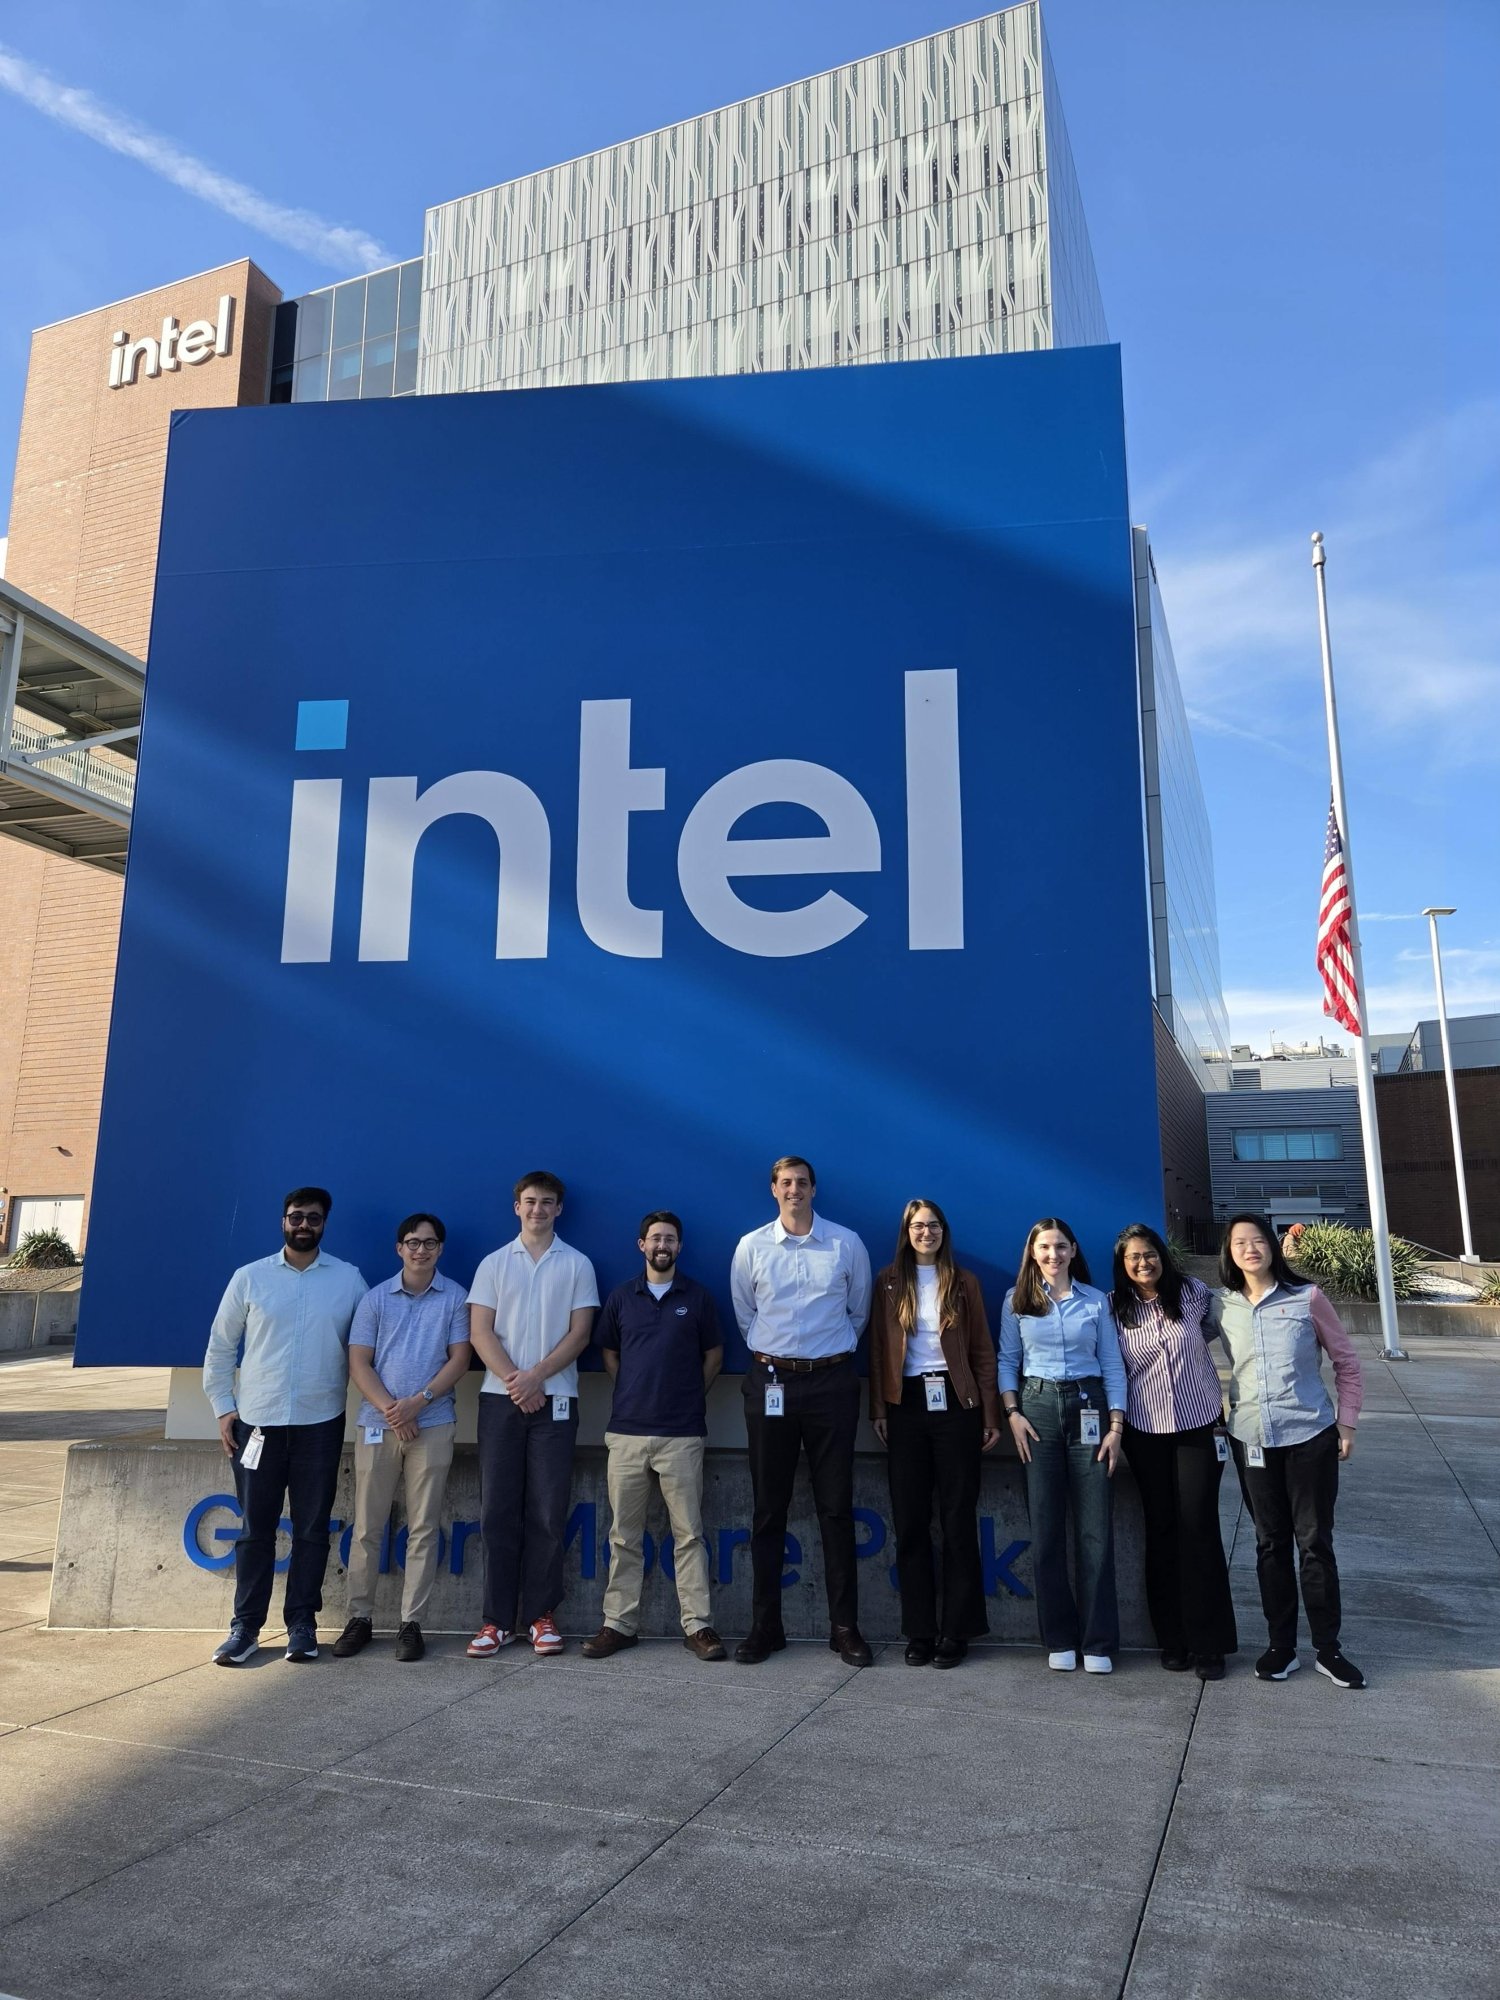
Conrad at the Intel sign at Gordon Moore Park in Hillsboro Conrad in a cleanroom suit Group photo in front of the Intel sign at Gordon Moore Park

More about this internship

Jun – Sep 2026

Talos Engineering

Automation Engineering Intern · Richland, WA

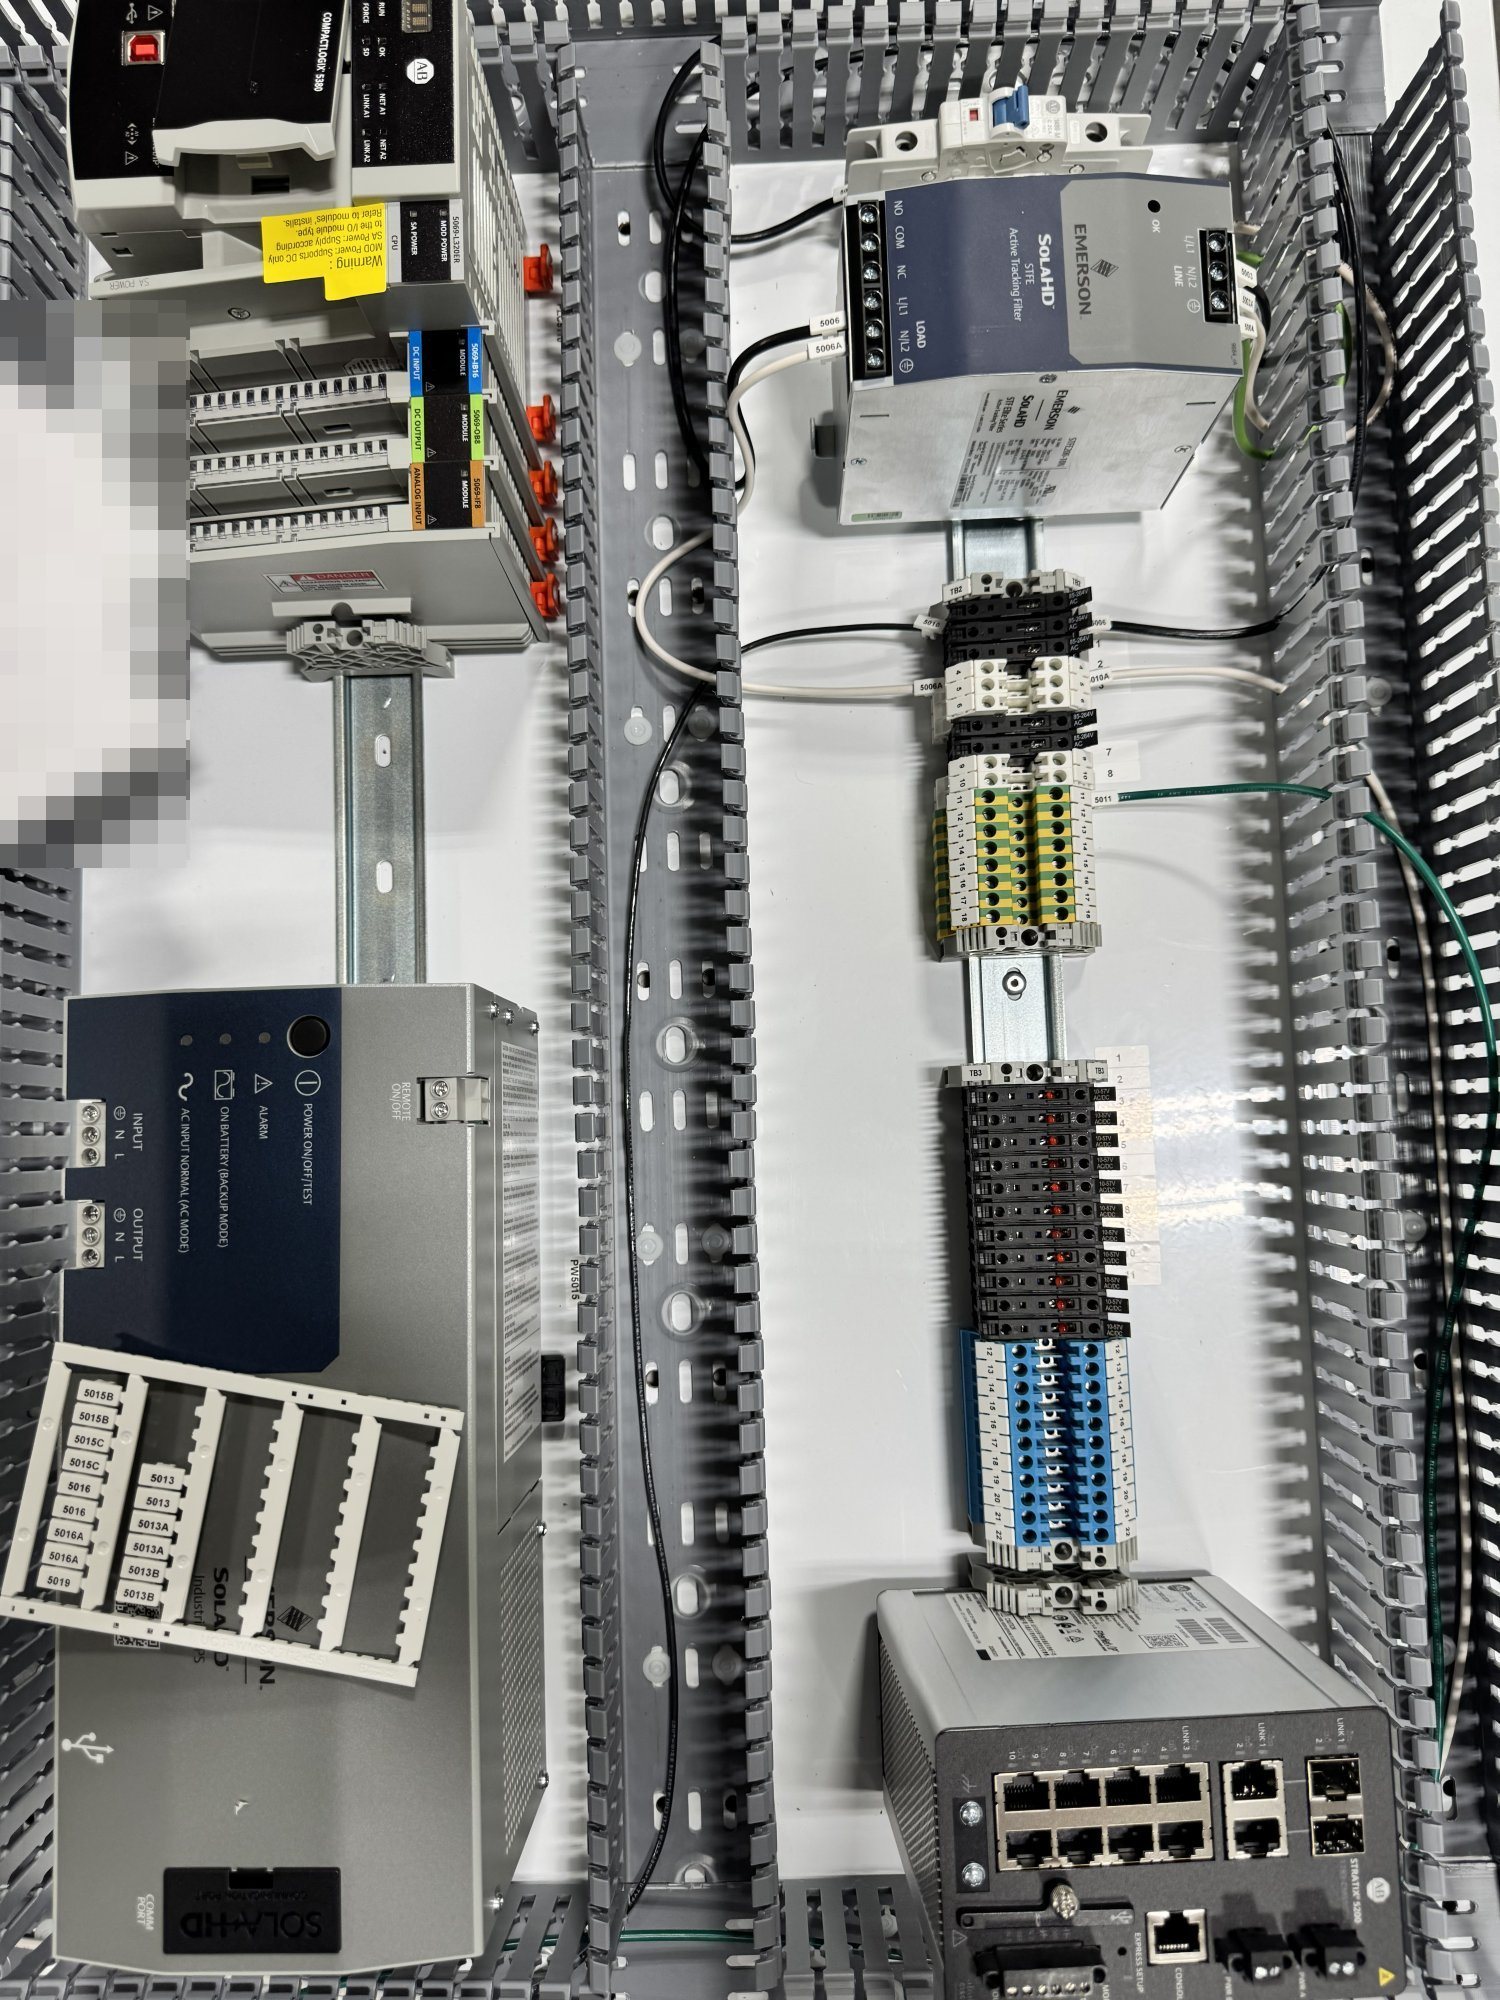
  • Developed and modified PLC ladder logic in Allen-Bradley Studio 5000 for automation and manufacturing applications
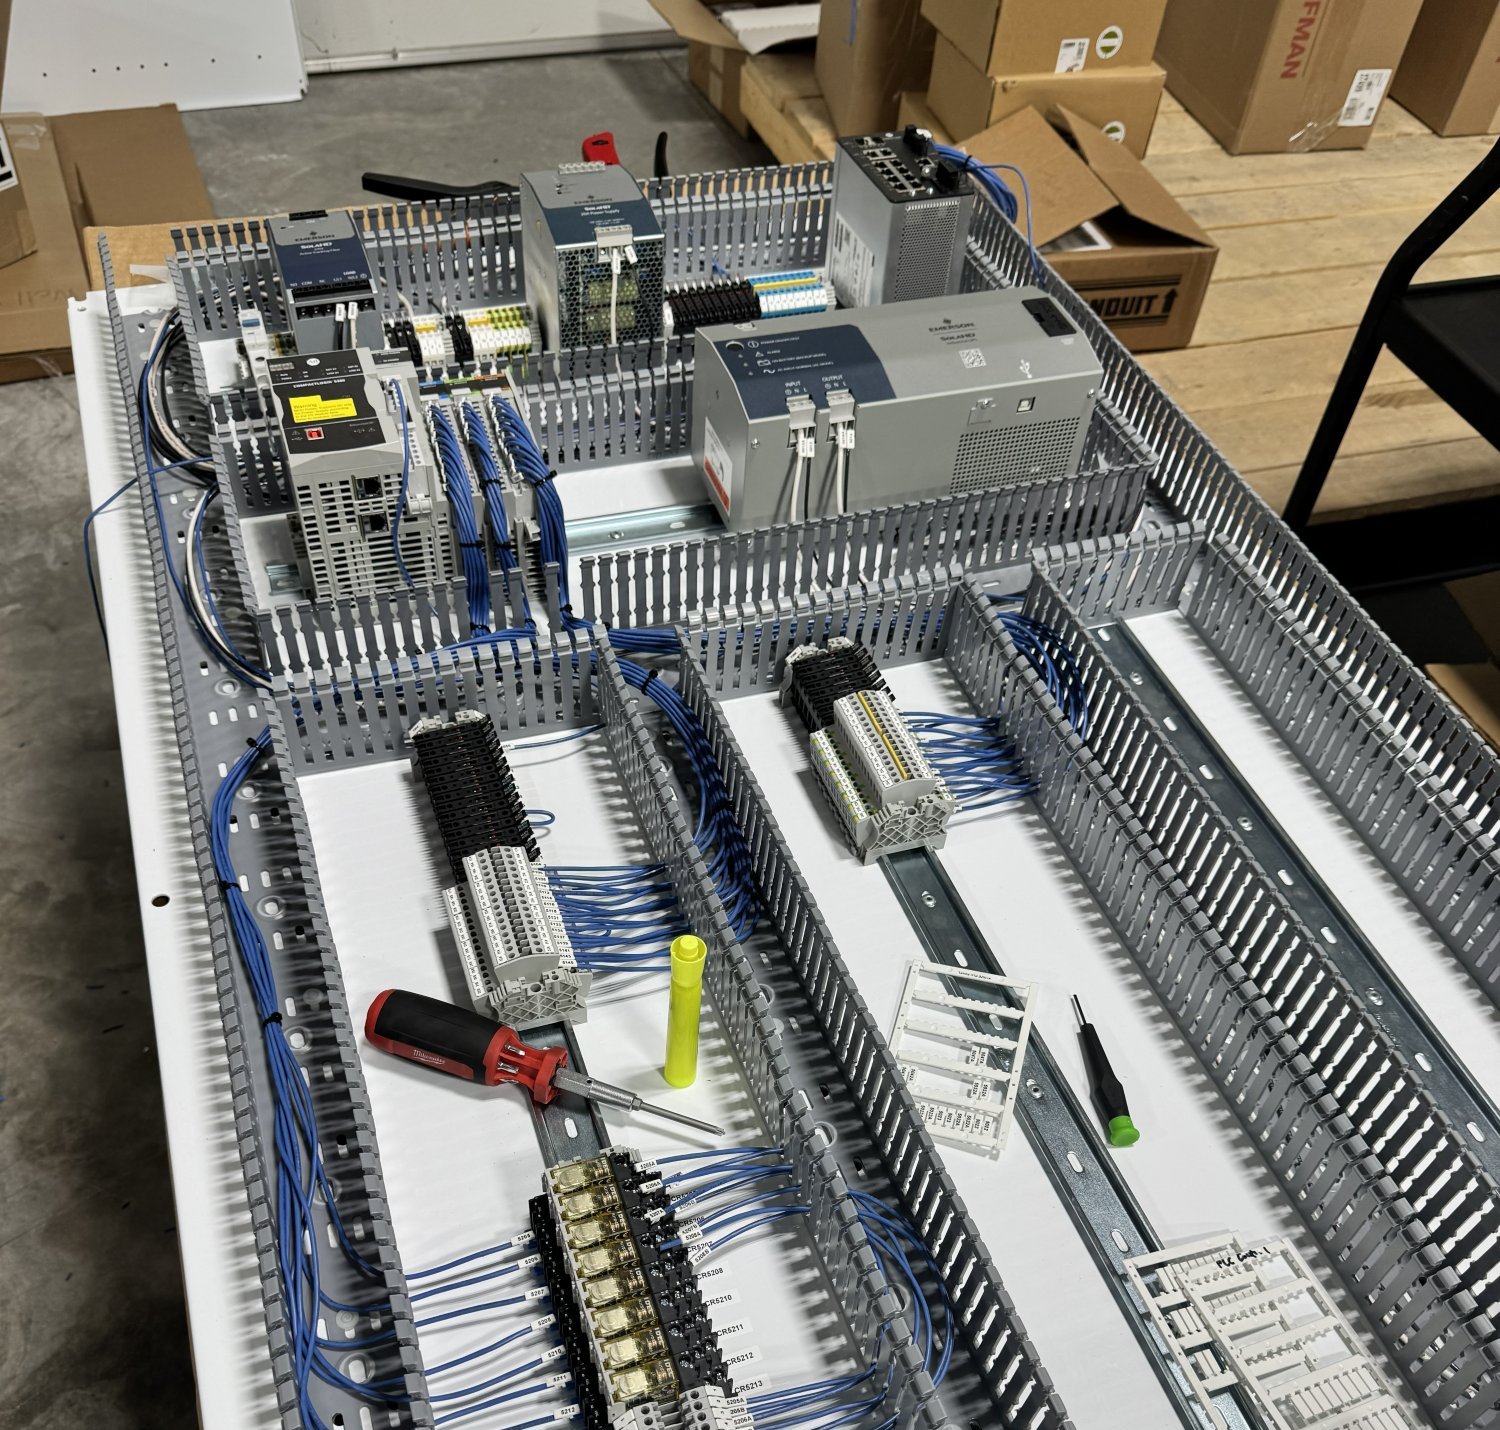
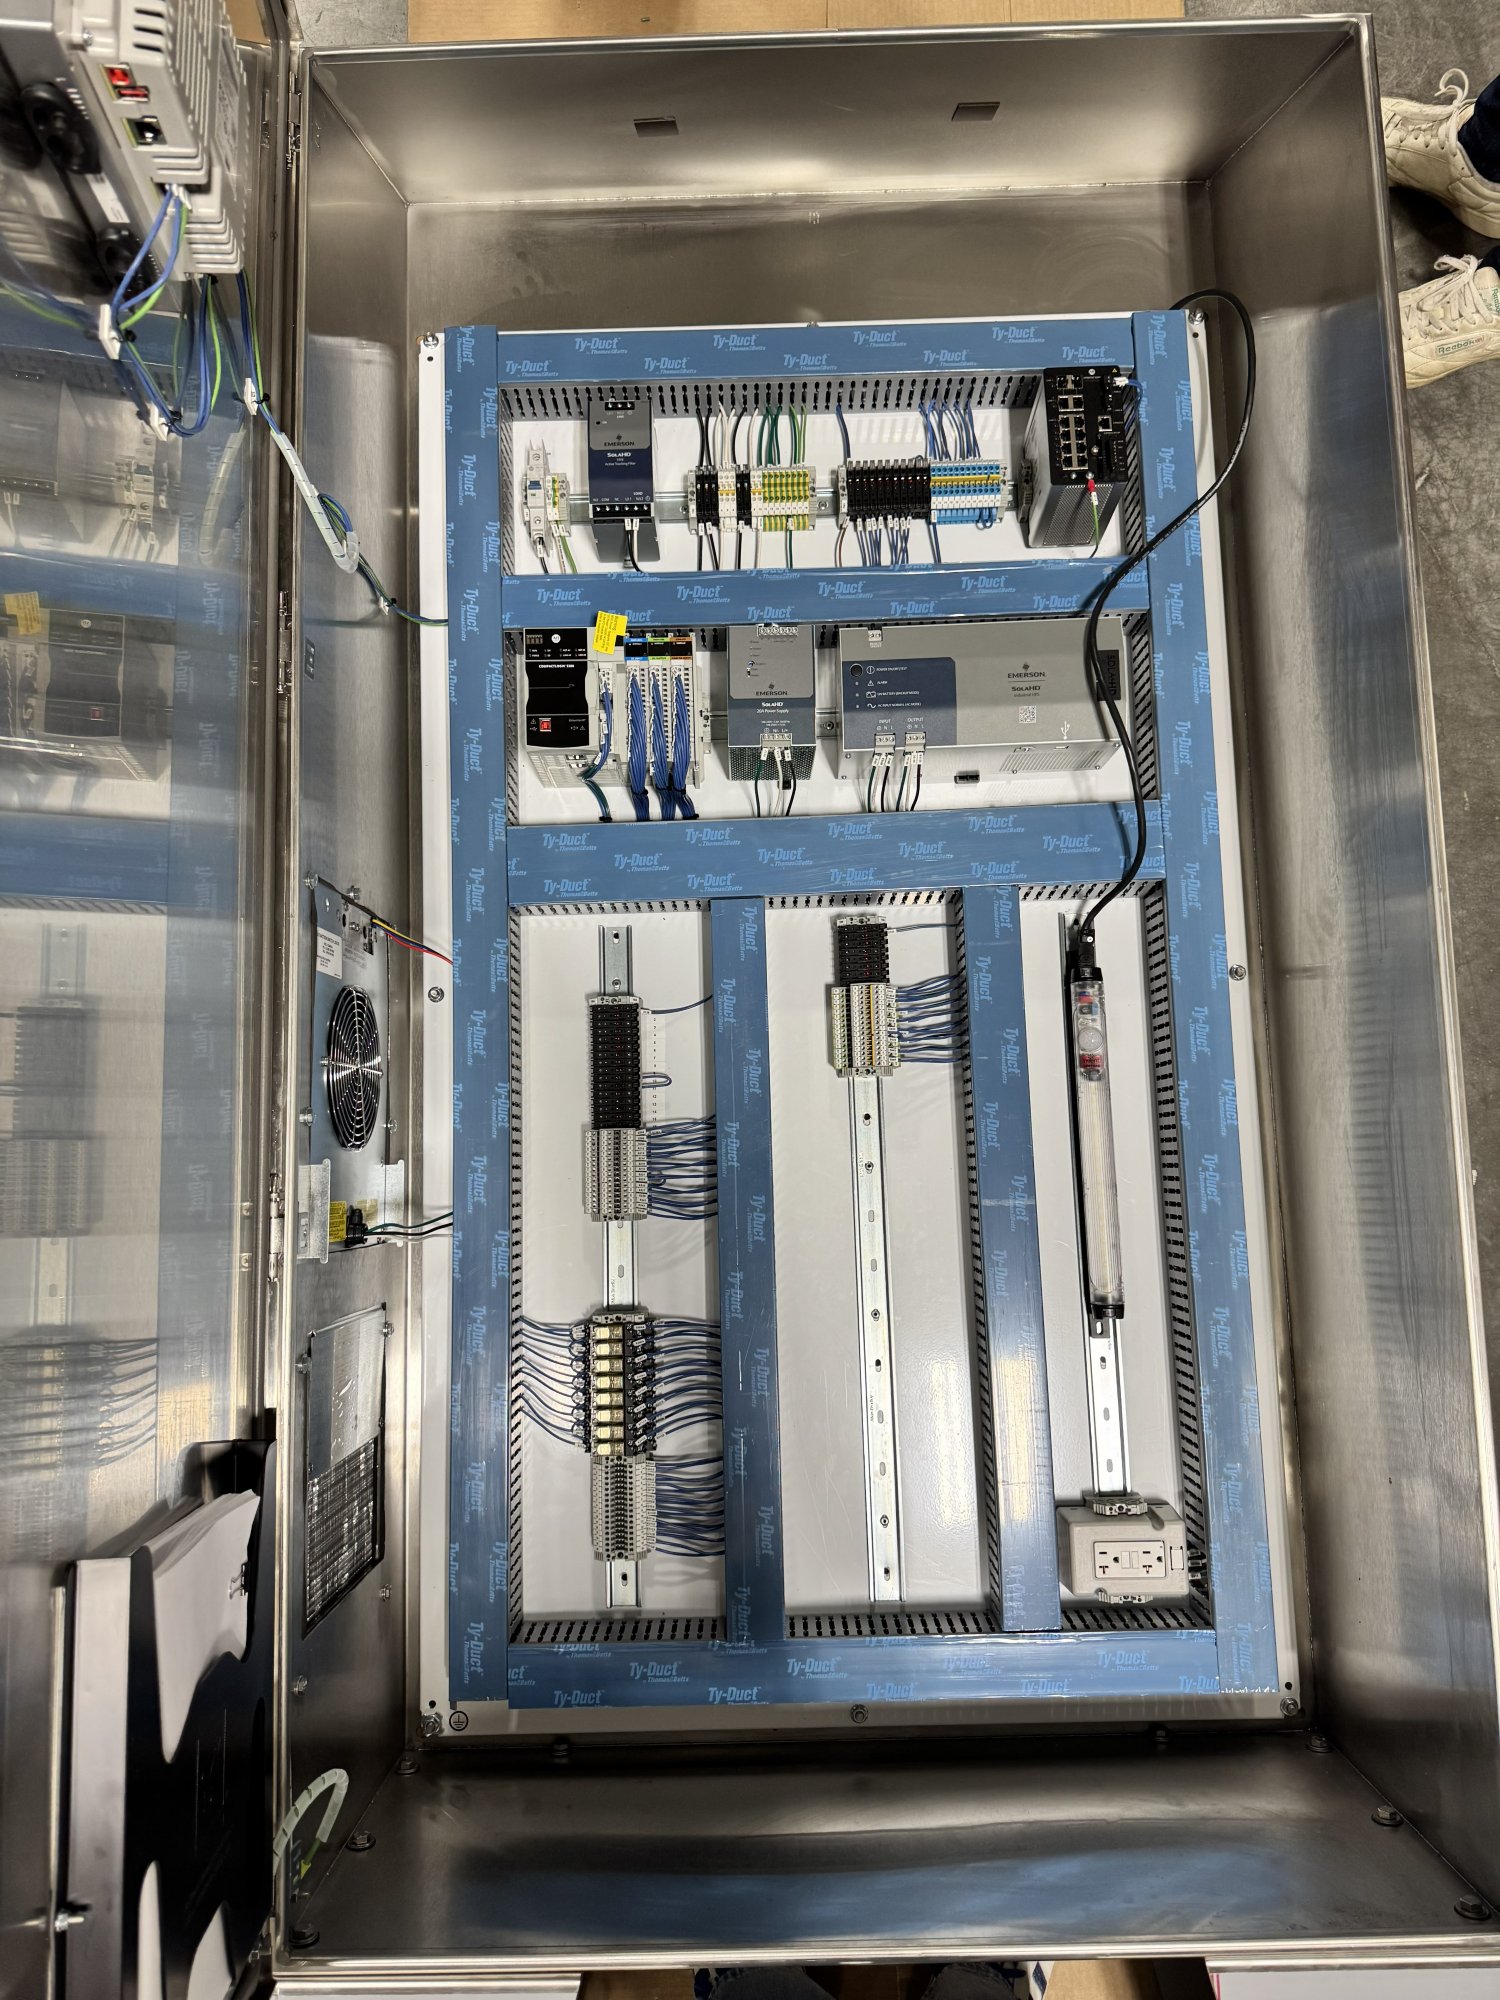
  • Physically assembled and wired industrial control panels from the engineering team's AutoCAD Electrical drawings, working from schematics, terminal diagrams, and component layouts
  • Worked with engineers to integrate sensors, actuators, and electrical controls into customer systems
Control panel backplane on a workbench mid-build Wired control panel backplane in an open stainless enclosure Close-up of labeled terminal strips in a control panel

Panel assembly photos and PLC work

Summers 2024 & 2025

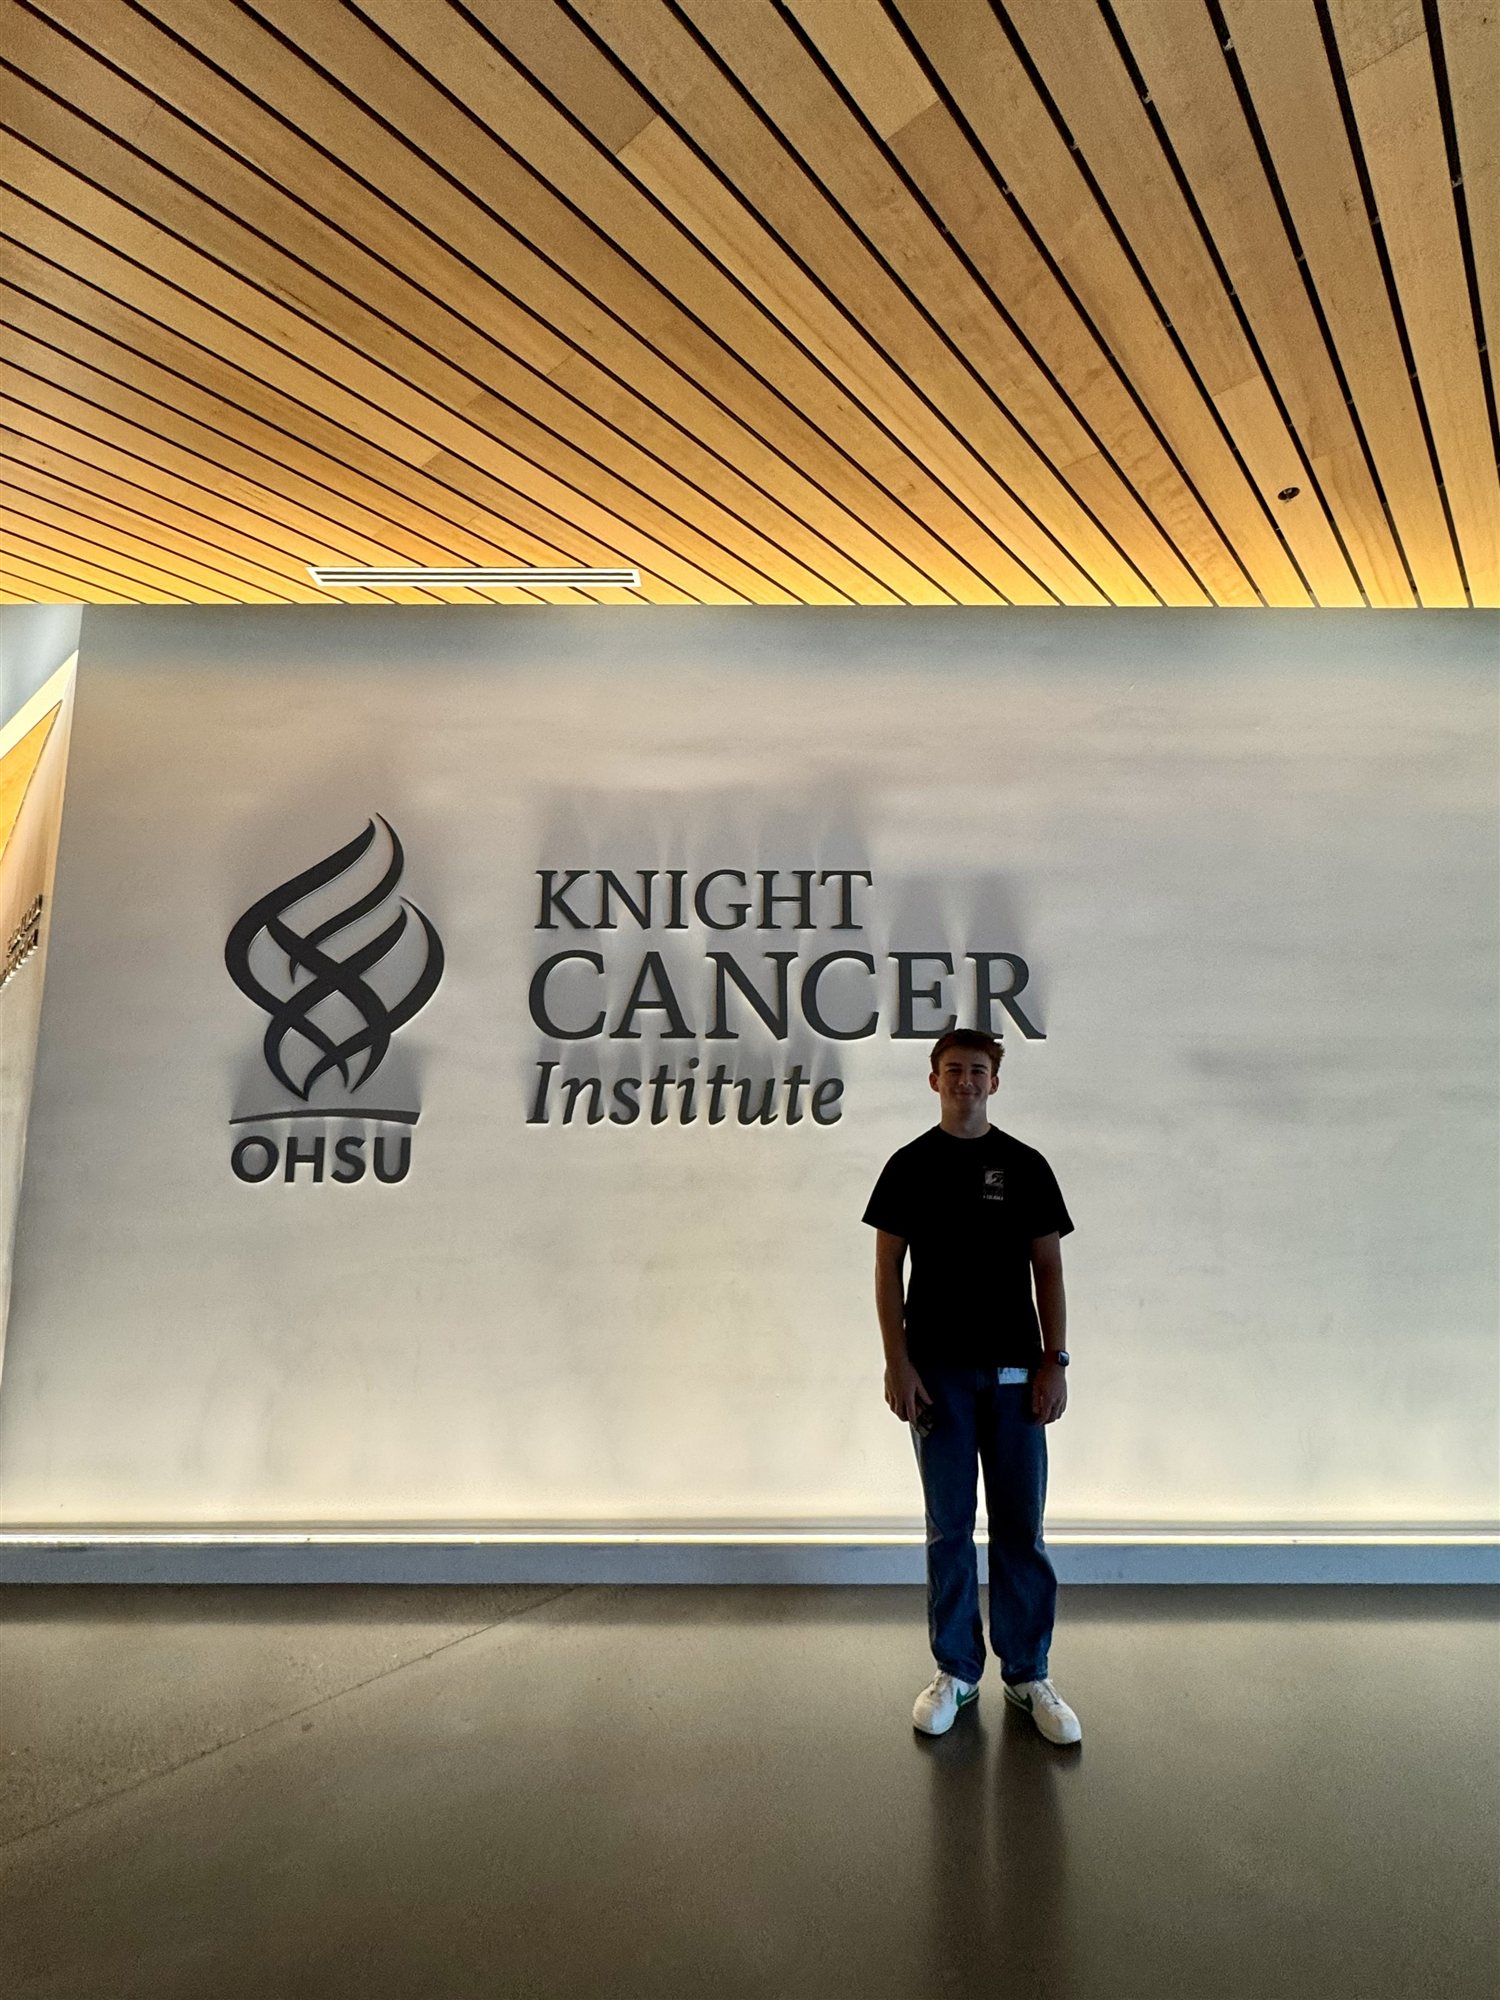
OHSU Knight Cancer Research Institute

Intern · Portland, OR

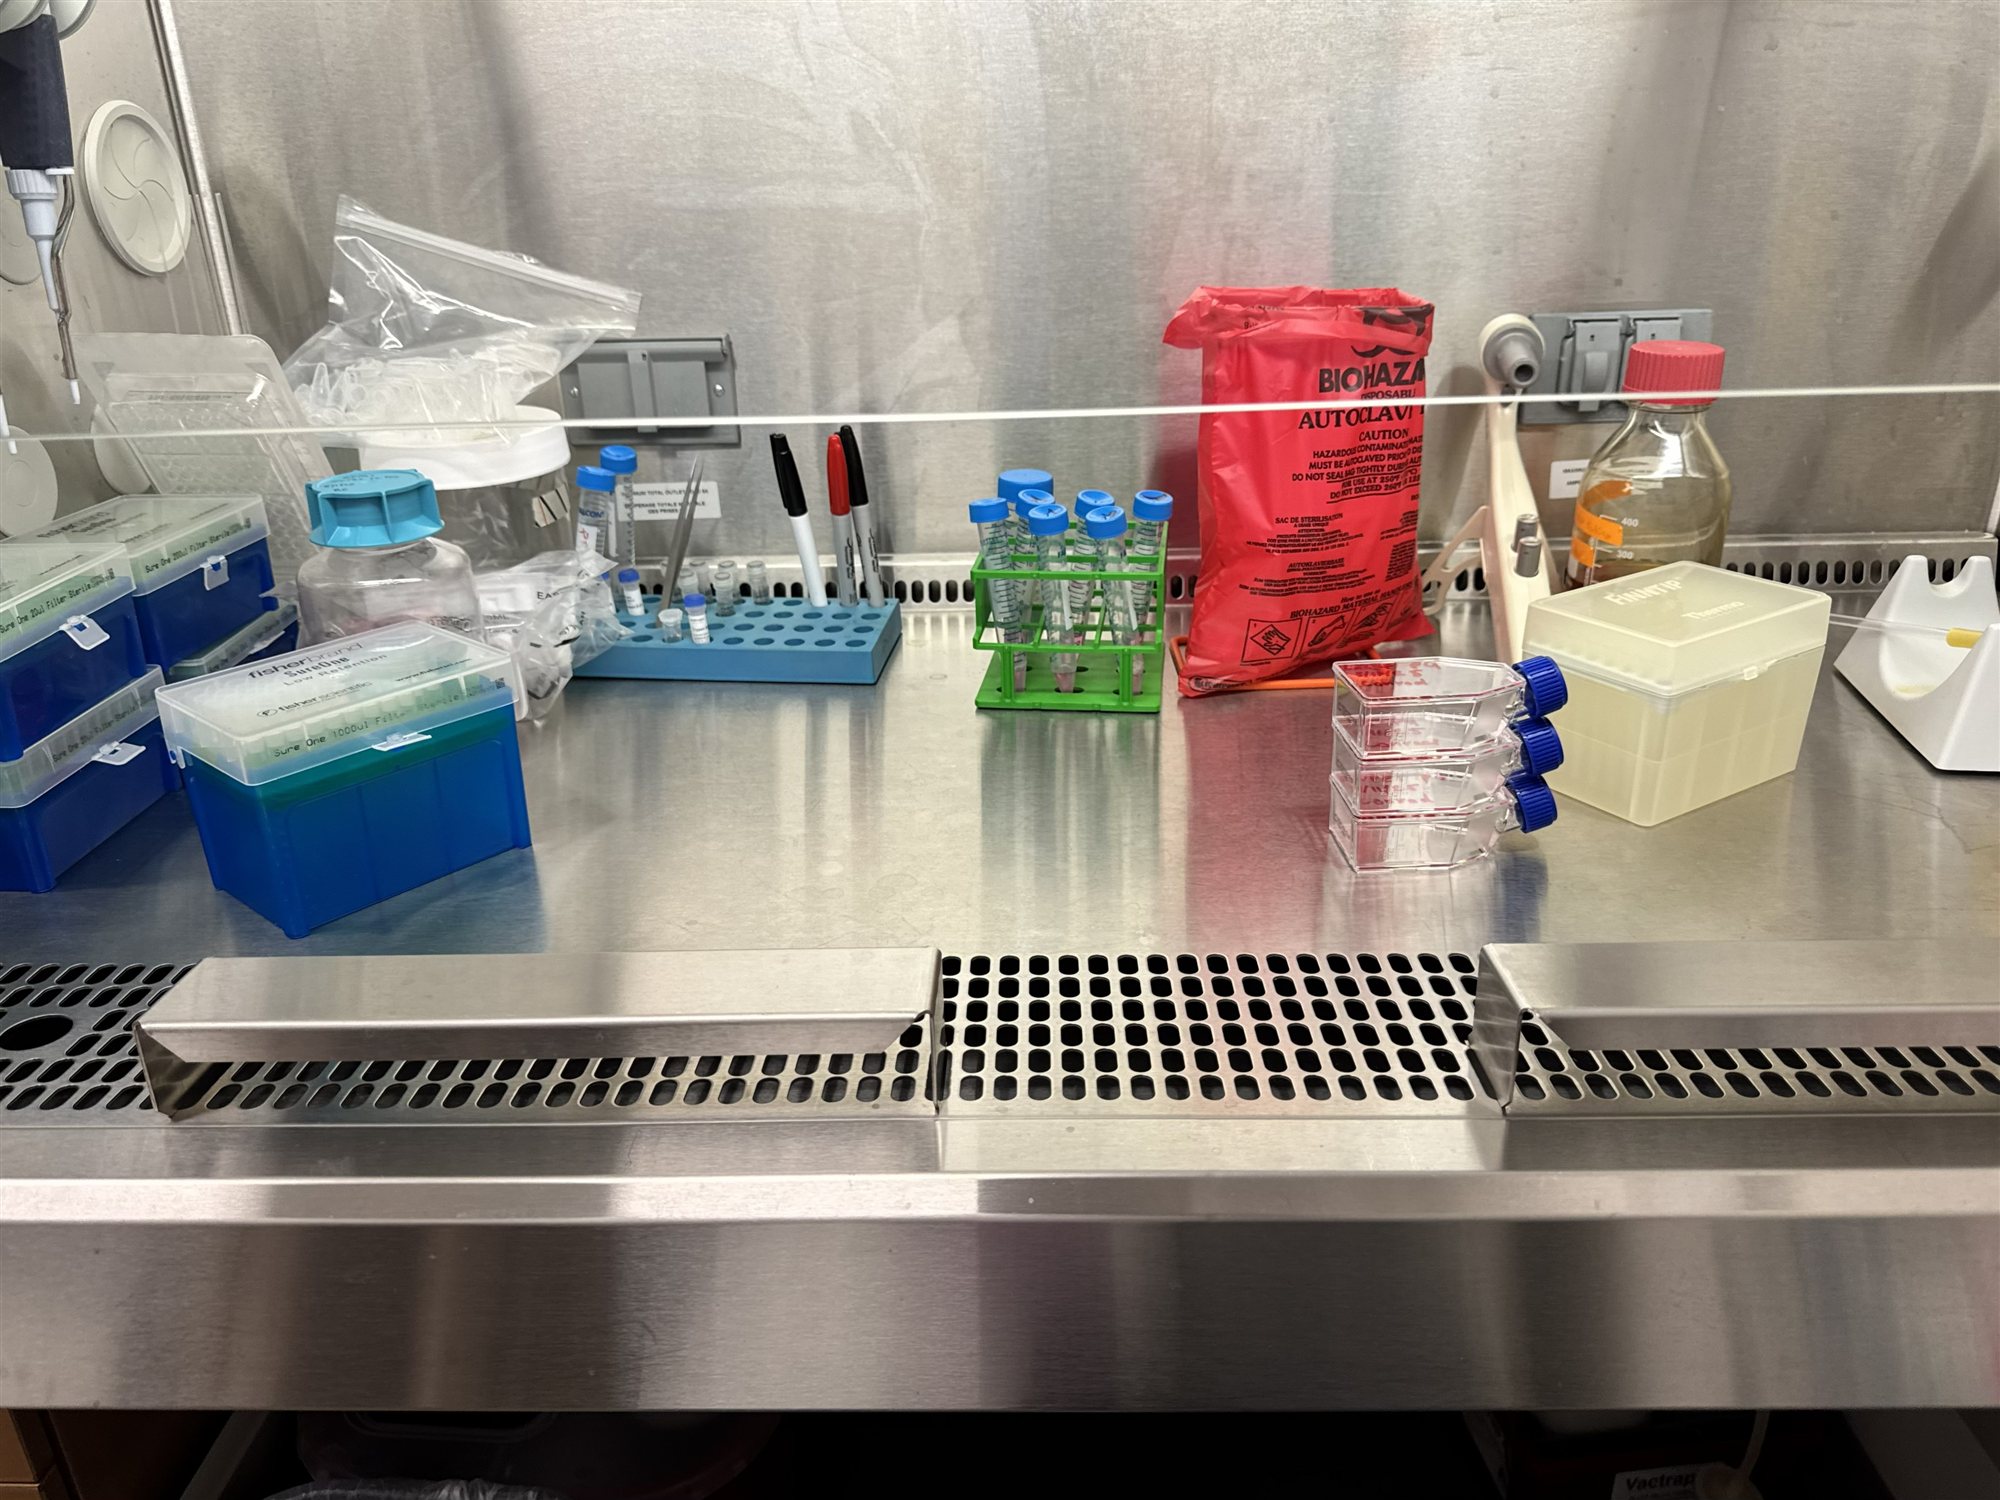
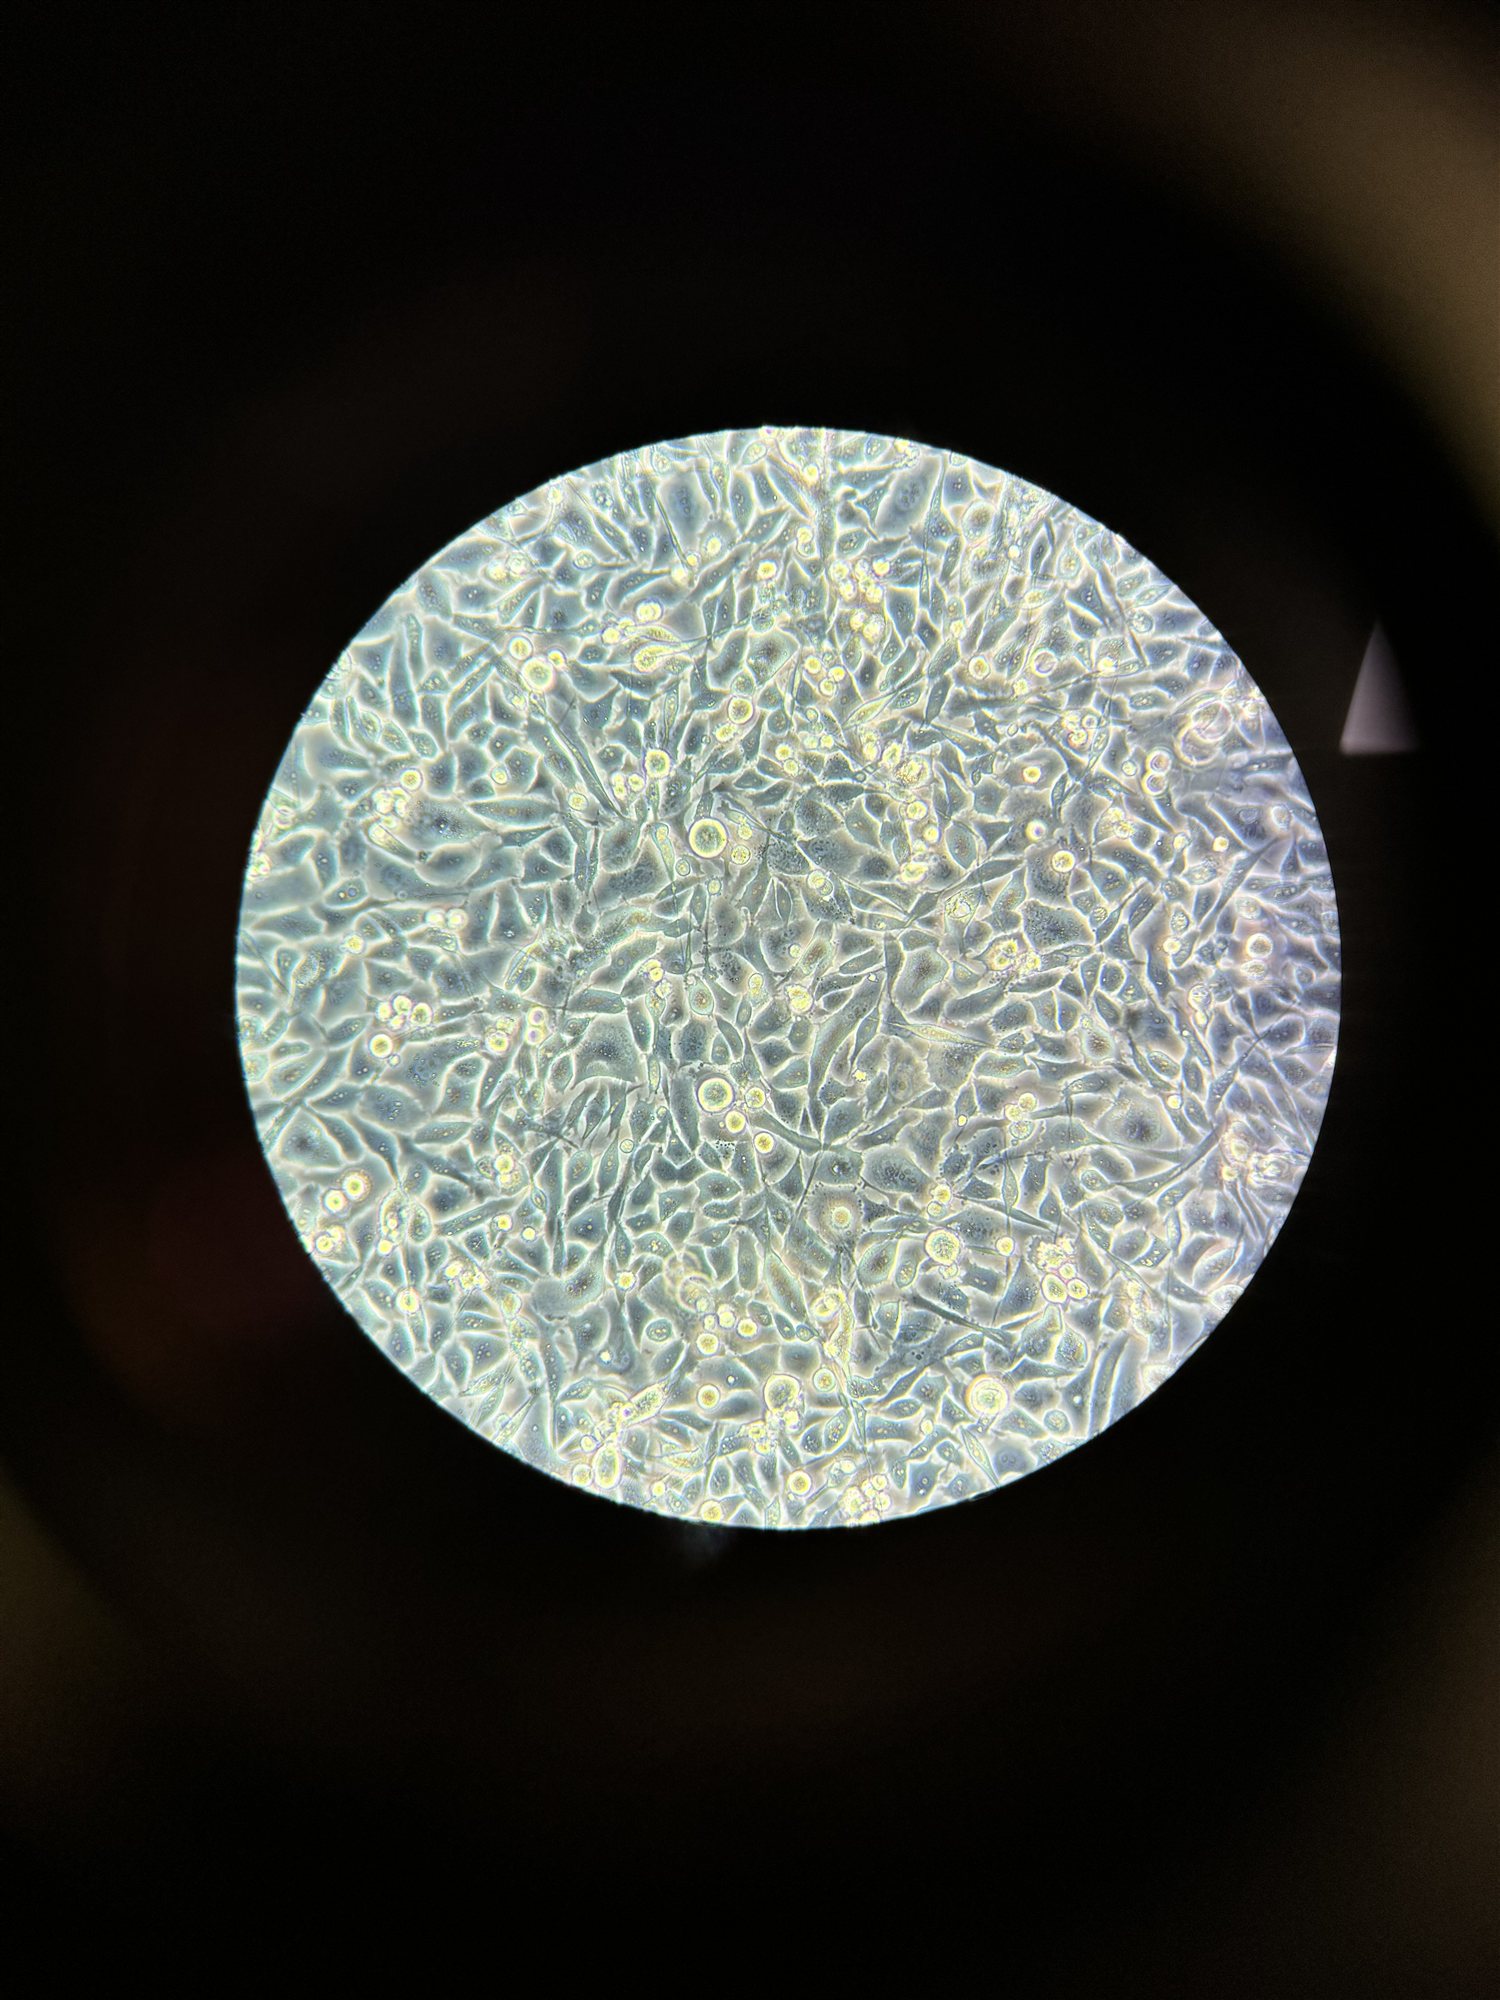
  • Maintained about 15 metastatic cancer cell lines through routine culture, sample prep, and biological assays
  • Sustained a CRISPR-knockout prostate cancer line with a 40× increase in proliferation over wild type, documented with Incucyte live-cell imaging
  • Assisted with murine surgical procedures and rat dissections for pancreatic cancer research
Cell culture setup in a biosafety cabinet Conrad at the OHSU Knight Cancer Institute Cultured cells under a light microscope

More about this research

Summer 2023

Sensobright Industries

Intern · Beaverton, OR

  • Fabricated about 20 mounting brackets for an SMT production line using laser cutting and hand tools
  • Helped engineers with CAD modeling, prototype fabrication, and documentation

Projects

Personal build · Jan 2026 – Present

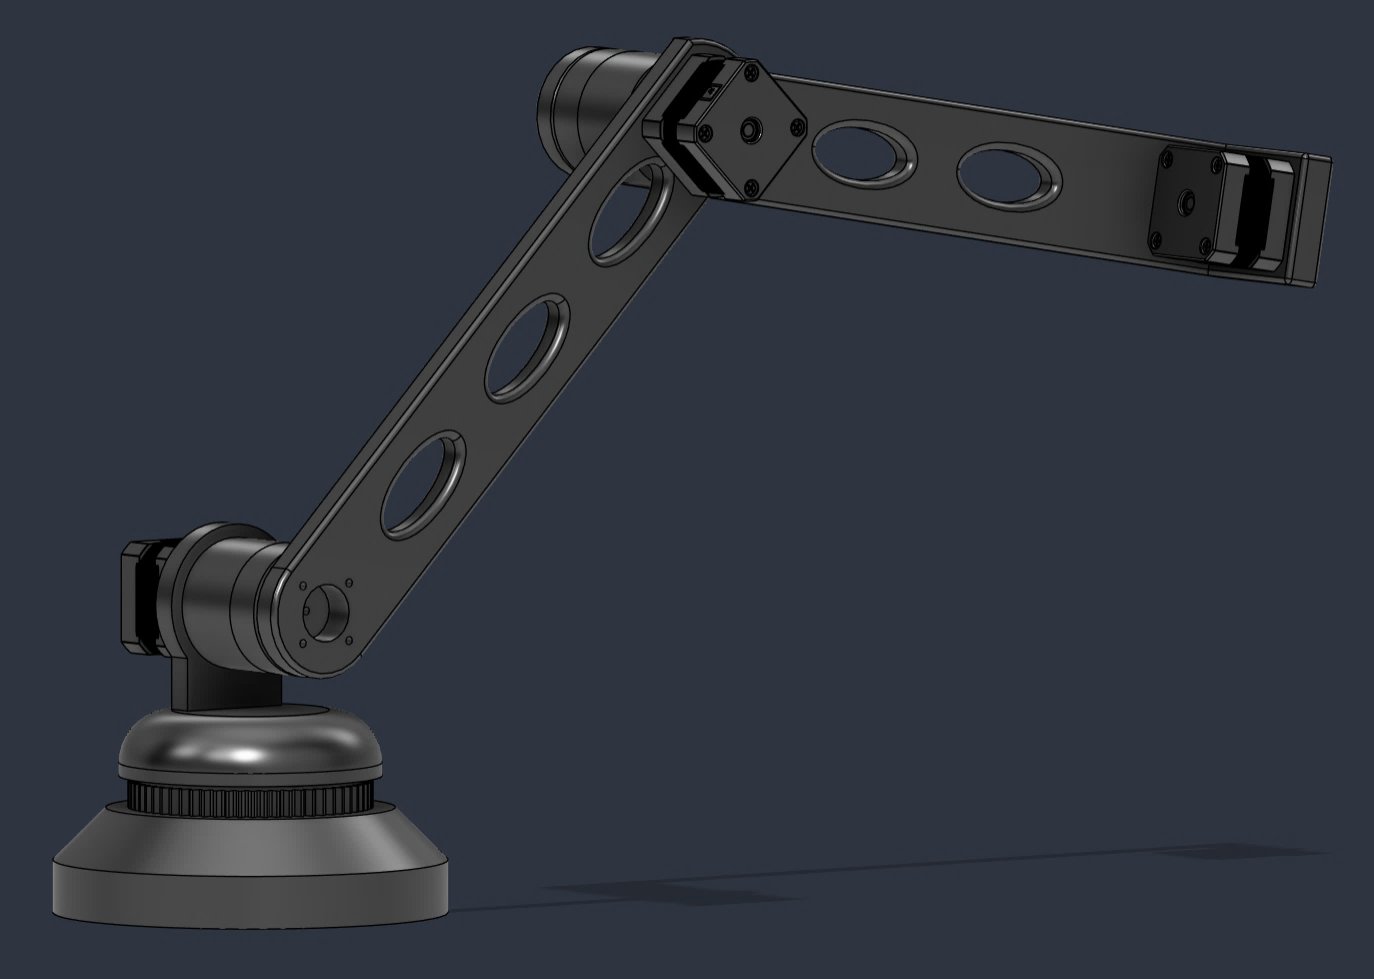
6-Axis Robotic Arm

A desktop arm I'm designing and building from scratch. I modeled the structure and joints in Fusion 360, print the parts on a Bambu P1S, and drive six NEMA 17 steppers through A4988 drivers from Arduino Uno controllers.

Actuation
NEMA 17 steppers, A4988 drivers
Control
Arduino Uno, open-loop step/direction
Built with
Fusion 360, Bambu P1S (FDM)

CAD and build notes

OSU Mars Rover Robotics Club · Apr 2026 – Present

Rover End-Effector and Science Hardware

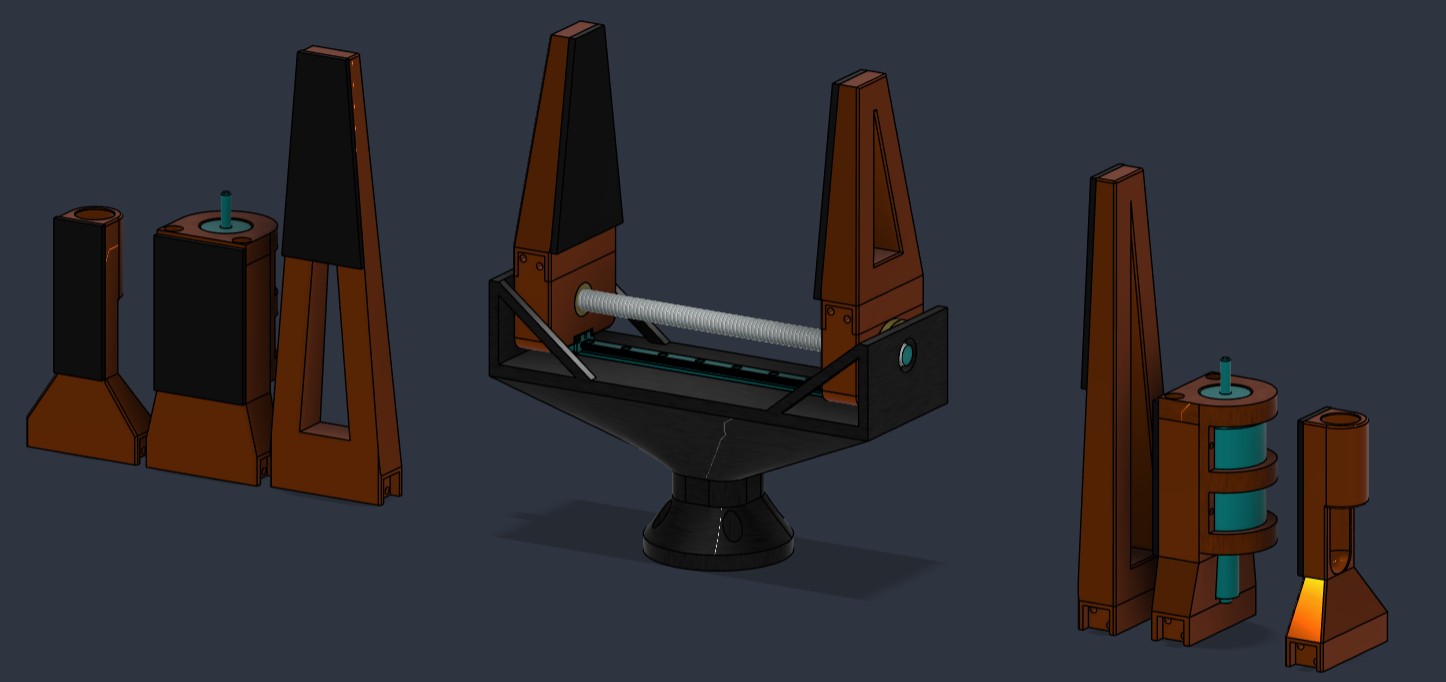
I lead the team designing a new end-effector to give the rover's arm more dexterity. Before that, I designed the spectrometer enclosure and a sample flask clamp for the science subsystem, built to survive off-road vibration with the tools the club actually has.

Role
End-Effector Team Lead
Work
Gripper research and requirements, spectrometer enclosure, flask clamp
Tools
Fusion 360, tolerance analysis, 3D printing

Design details

Simulation · In progress

UR10 Arm in Zero Gravity

Simulating a UR10 in MuJoCo, starting with a fixed base and working toward free-floating base dynamics, target capture, and motion planning.

Project plan

Data analysis · May – Jun 2025

Back Bay Water Quality

Analyzed 1994–2018 water temperature, air temperature, and water depth data in Python. Water temperature rose 2.8% over the period even as air temperature fell 3%.

Analysis

Skills

CAD
Fusion 360, SolidWorks, Siemens NX, Autodesk Inventor; tolerance analysis
Industrial automation
Allen-Bradley Studio 5000, PLC ladder logic, control panel build and wiring, reading AutoCAD Electrical drawings
Embedded and robotics
Arduino, microcontroller-based stepper control (A4988), MuJoCo
Semiconductor manufacturing
Automated wafer handling, equipment troubleshooting, contamination control, process data review
Programming and data
Python (pandas, NumPy, Matplotlib), SQL, Toad, Git
Fabrication
3D printing, laser cutting, drilling, grinding, tapping
Wet lab
Cell culture, sterile technique, cell staining, light microscopy, Fiji/ImageJ
Languages
English, Spanish

Education

Oregon State University

B.S. Mechanical Engineering, Robotic Control Option · Corvallis, OR

Expected
June 2028
GPA
3.85 / 4.00
Standing
Junior
Honors
Dean's List, 5 terms
Coursework
Linear Algebra, Dynamics, Computational Methods, Circuits, Materials Science
Organizations
Robotics Club (Mars Rover Team), Biomedical Engineering Society, Club Lacrosse

Contact

I'm looking for Summer 2027 internships in robotics, automation, controls, hardware, and manufacturing. Email is the fastest way to reach me.

conradkelsay@gmail.com

linkedin.com/in/conradkelsay Resume